Project
- Stars
- Started
- Issues
- License
Plan arm movements with MoveIt and ROS 2
This SO-101 stack connects the arm to MoveIt 2 for planning and executing movements. It includes Gazebo simulation, an RViz control interface and leader-to-follower teleoperation, so you can check a planned movement in software before trying it on the physical arm.
Build it on Ubuntu 24.04 with ROS 2 Jazzy and calibrate each arm with LeRobot first. This is a recent source-based robotics project; follow its read-only hardware check and supervised first-run procedure. Custom name prefixes are not yet supported by the MoveIt and controller configuration.
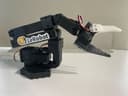
SO-101 robot arms
SO-101 follower arm (partly) and SO-101 leader arm (partly)
SO-101 follower arm: ROS 2 Jazzy source build; requires LeRobot calibration
SO-101 leader arm: Leader teleoperation with a calibrated follower
How did it go? Tips, problems, questions…
Plan arm movements with MoveIt and ROS 2
This SO-101 stack connects the arm to MoveIt 2 for planning and executing movements. It includes Gazebo simulation, an RViz control interface and leader-to-follower teleoperation, so you can check a planned movement in software before trying it on the physical arm.
Build it on Ubuntu 24.04 with ROS 2 Jazzy and calibrate each arm with LeRobot first. This is a recent source-based robotics project; follow its read-only hardware check and supervised first-run procedure. Custom name prefixes are not yet supported by the MoveIt and controller configuration.
adoodevv
On GitHub
SO-101 robot arms
SO-101 follower arm (partly) and SO-101 leader arm (partly)
SO-101 follower arm: ROS 2 Jazzy source build; requires LeRobot calibration
SO-101 leader arm: Leader teleoperation with a calibrated follower
Feedback
How did it go? Tips, problems, questions…